Manipulator
Client :
-
Date :
2026
Idea
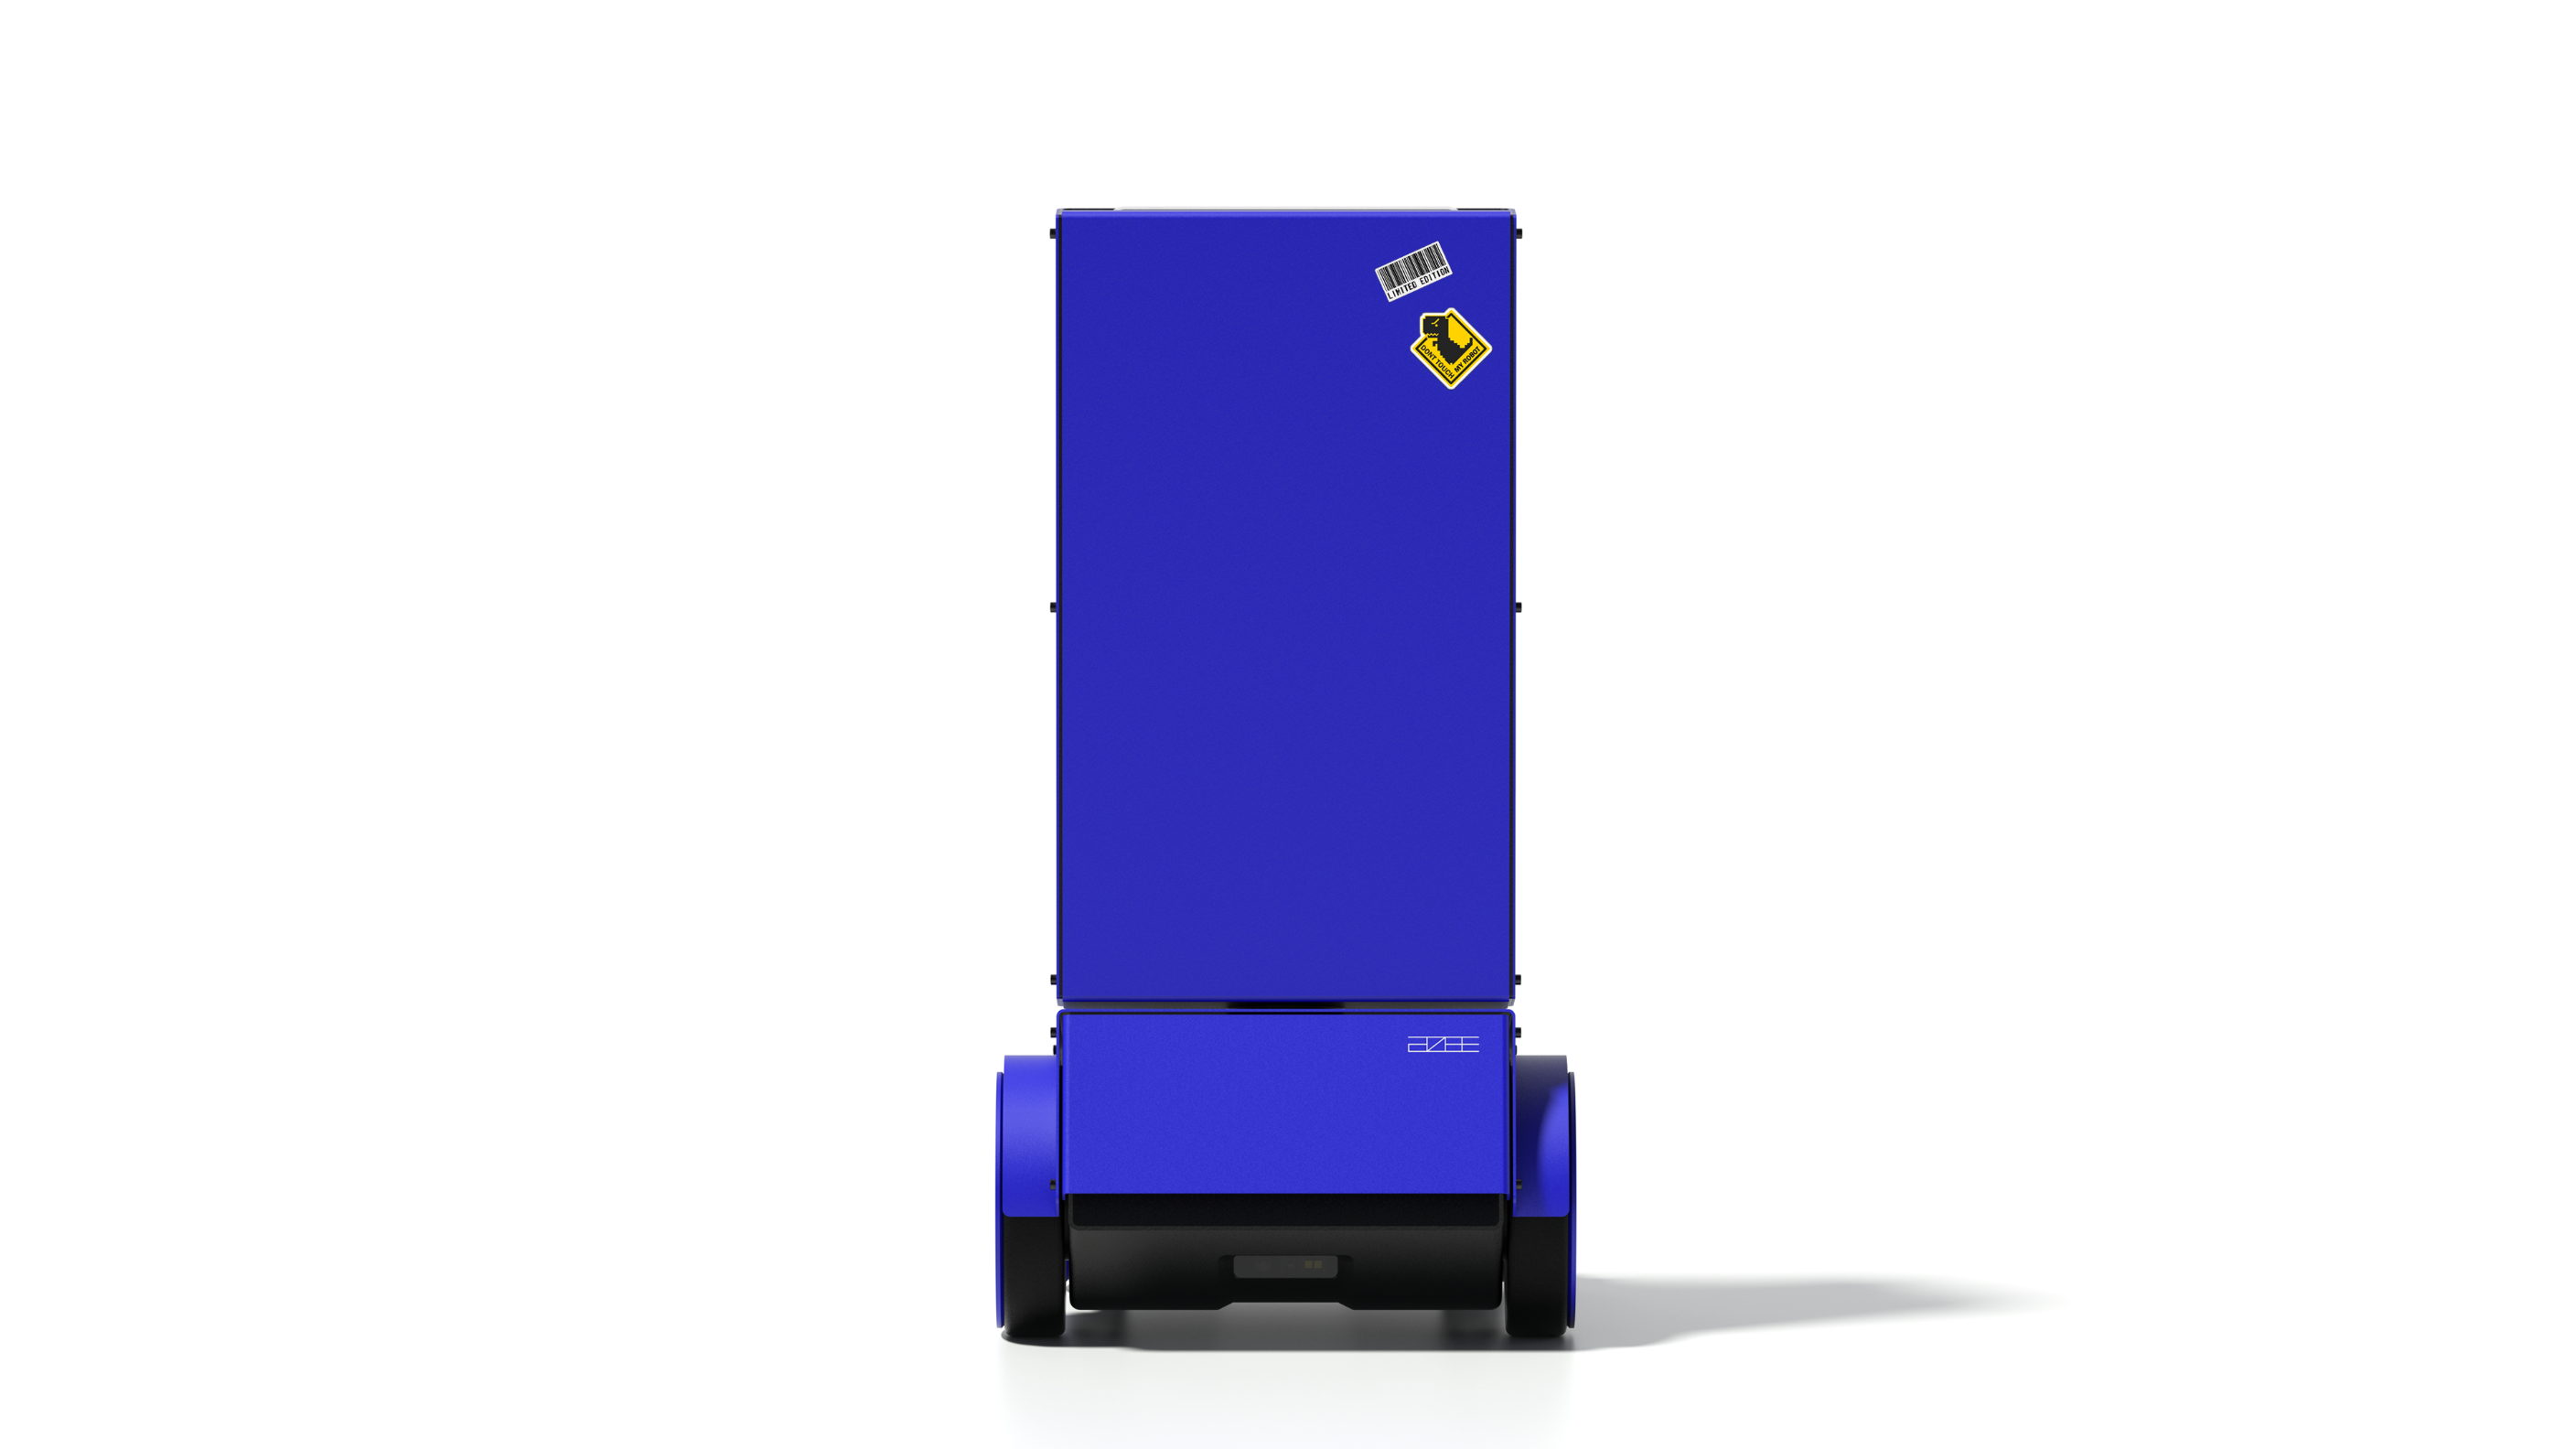
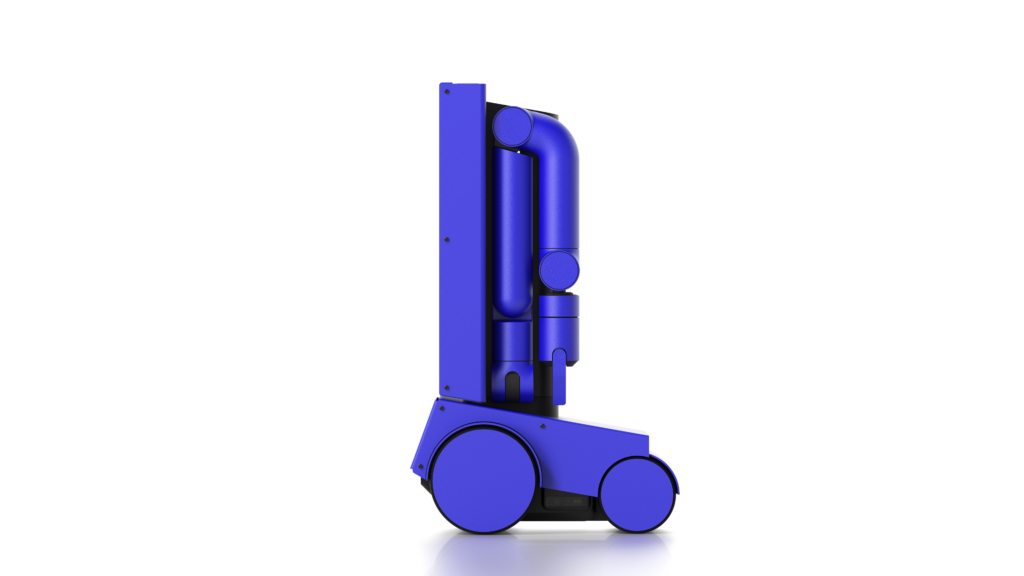
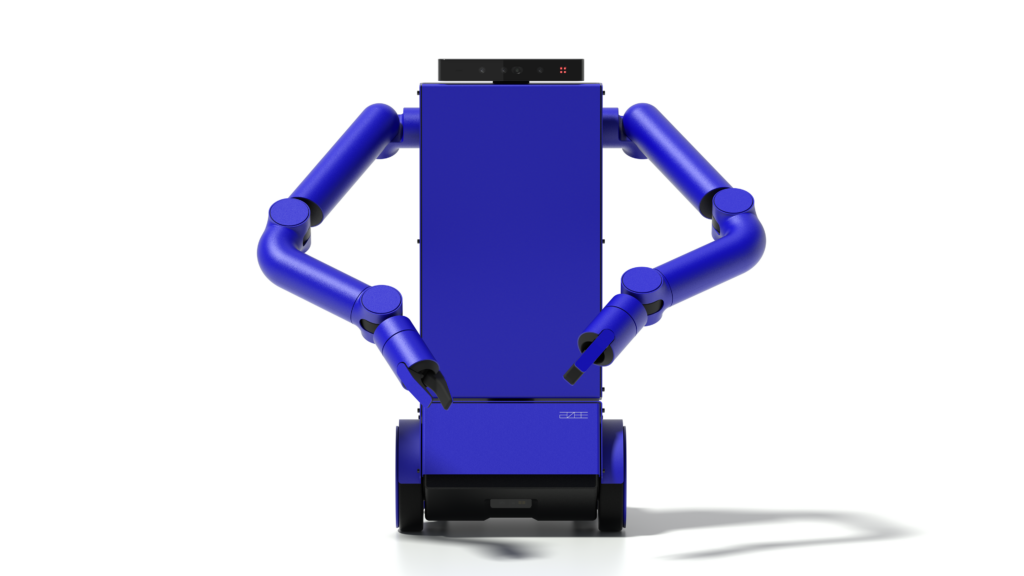
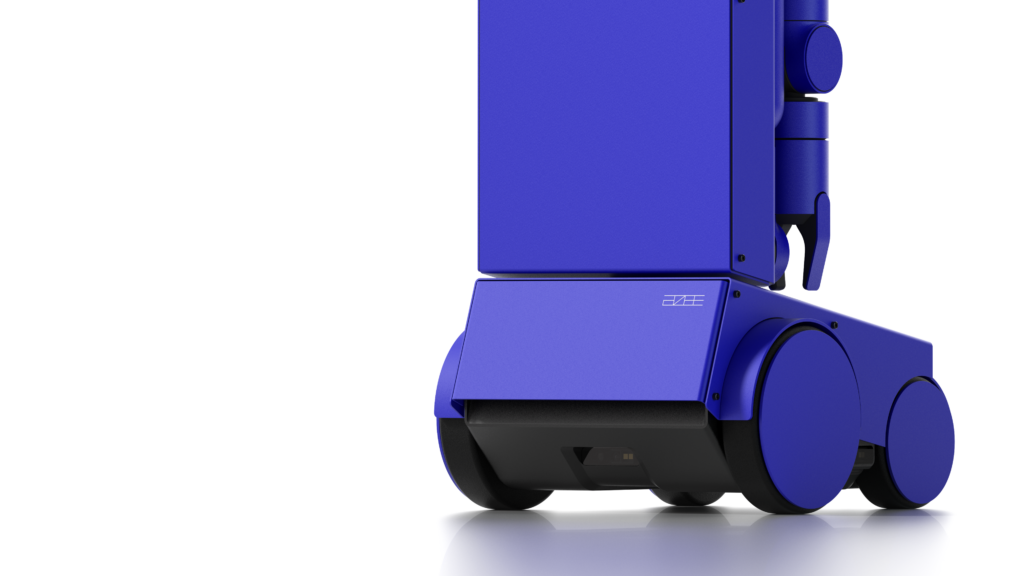
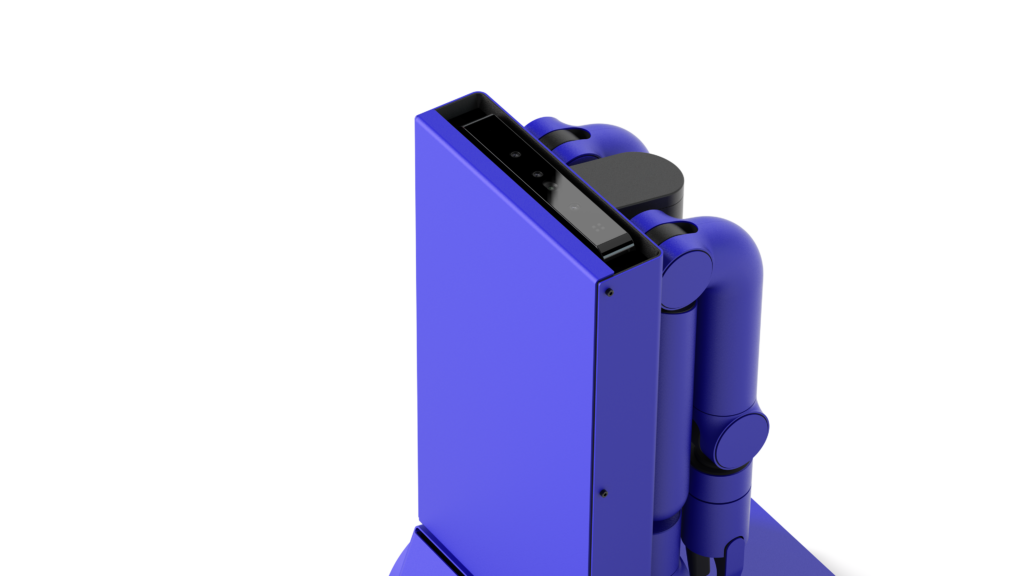
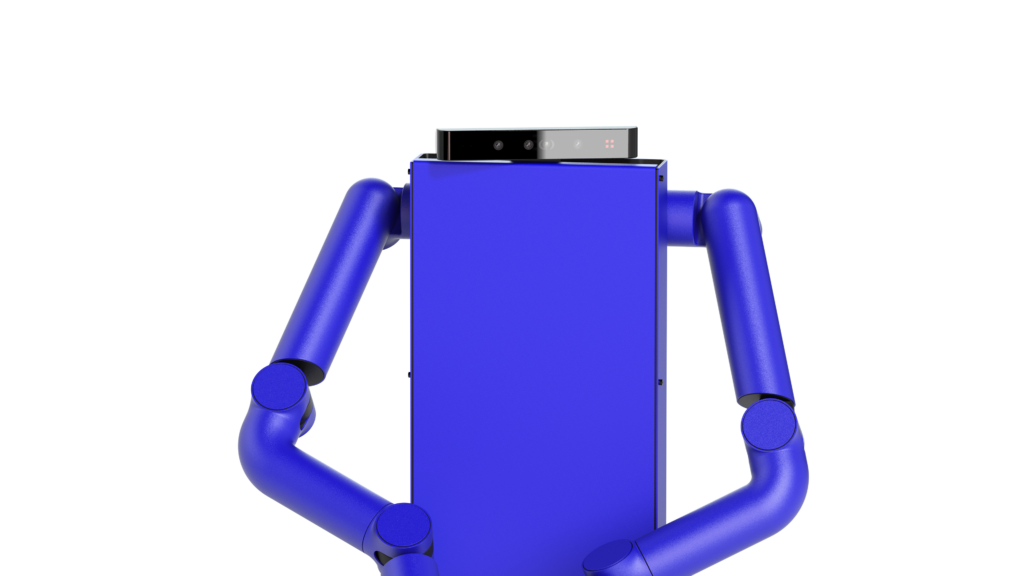
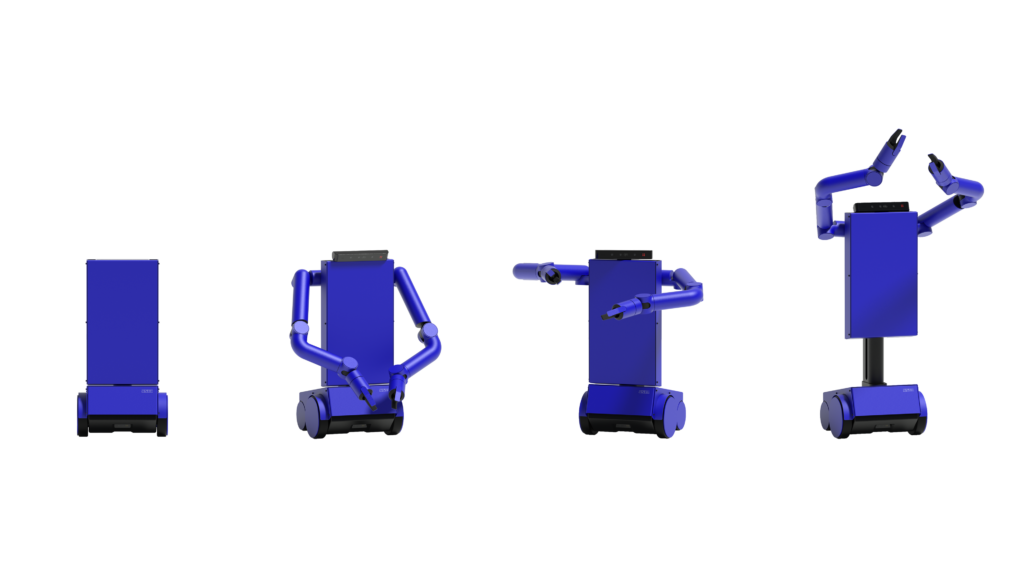
This mobile dual-arm robot combines a slim, upright body with articulated arms and a wheeled base, integrating mobility and object handling into a unified design. By transitioning between a compact, stowed form and an expanded working configuration, the design balances spatial efficiency with functional flexibility.
Form
The contrast between the rectilinear body and softly rounded arm segments gives the mechanical structure a sense of clarity and fluidity.
Function
The arms fold neatly behind the body for transport or standby, maintaining a compact silhouette. During operation, the arms and upper sensor module deploy, while the height-adjustable body accommodates tasks at different working heights.